

Your shopping cart is empty!
FDM 3D PrintersResin 3D printers3D scanner3D Pens3D Printing filaments3D Printing resin3D Printer maintenance and cleaning3D Printer parts3D Filament DryerUV printers
Raspberry Pi 5 and kitsRaspberry Pi 4 and kitsRaspberry Pi 3B+ and kitsRaspberry Pi 400/500Raspberry Pi Zero and accessoriesRaspberry Pi PicoRaspberry Pi CMScreens for Raspberry PiRaspberry Pi Camera modulesCases for Raspberry PiHAT extension for Raspberry PiRaspberry Pi accessoriesPower Supply for Raspberry PiRaspberry Pi memory cards with NOOBS
STM32 MicrocontrollersATmega microcontrollersFlipper ZeroTeensy - ARMAdafruit FeatherESP8266 / ESP32 WiFi ModulesM5Stack controller and accessories
CoDroneUnitree RoboticsDobotOzobotEducational kits for beginnersEducational kits for advancedRobotic Arm / ClawRobot Chassis and Accessories
Sensors - modulesWireless Communication ModulesRelay modulesDisplays and ScreensProgrammers and convertersVoltage RegulatorsPrototypingPassive electronic componentsActive electronic componentsSwitchesElectromagnets and solenoidsWearable electronics and materialsCoolingBasic Starter Kit
Motor controllersServo motorsDC motorsStepper motorsVibration MotorsBrushless MotorsElectric Linear Actuators and CylinderWater pumpsElectric motors accessoriesWheels and mounting parts for motors
AC voltage stabilizerAdjustable Lab Power SuppliesInverters DC/ACUninterruptible power supplyAlkaline BatteriesRechargeable batteryBattery Chargers Ni-Mh / Ni-Cd / Li-Ion / Li-Pol / Li-FeLi-Ion battery charging and balancing boardsAC/DC Mains powers supply adapterPower Supplies AC/DCConnection Cables, ExtendersBatteries for power toolsPlug adapter EU/UK/USCharger for Electric Bikes
Soldering toolsBattery Welding Machines and accessoriesMeasuring equipmentChemicalsTweezersElectric toolsScrewdrivers and wrenchesHot Glue GunPlier and cutting nipperInsulation removal and crimping toolKnives and scissorsMagnifying glassesFlashlightStorage boxes and OrganizersUltrasonic cleanersLabel printersTool AccessoriesPackaging Tools and Materials
CNC machines and accessoriesAluminum Extrusion ProfilesLinear ActuatorBrackets and Other Accessories for Aluminium ProfilesLinear guides and garriagesRollers on supportsTrapezoidal Screws and NutsLinear Steel RodsLinear bearingsBearingsTiming BeltsTiming PulleyLinear Rod SupportSpindle motors, converters and mount bracketsScrews and NutsCable ChainsDrills and CuttersPneumatic Accessories
AEON Laser Engraving Cutting MachineFiber Metal Marking LaserCO2 Galvo engraving-marking machineUV Marking machinexTool LASER AND BLADE CUTTING MACHINEDiode laser engraving laserLaser machine spare parts and accessoriesEngraving MaterialsLightBurn Software
Smart Control DevicesSecurity camerasGate Automation SystemsSmart LightingClimate ControlSmart Locks and Access ControlDoor bellsRobot Vacuum CleanersSmart devices for pets
Video cables and connectorsAudio cables and connectorsSpeakersSpeakers activePortable speakersAudio amplifiersAudio and video convertersMixing DesksProjectors
USB AdaptersUSB cablesUSB HUBNetwork equipmentData storages and their accesoriesComputer CoolingKeyboardsMousesMicrophonesGamingLaptop AcessoriesComputer Power SuppliesCable OrganizersMonitorsWebcamsUPS Uninterruptible power supplyOther Computer Accessories
Power BankHeadphonesMobile phone chargersPhone casesSelfie stickSmart WatchesMobile PhonesPhone batteriesTablets
Jump StartersCar Dash CamerasPhone holdersCarPlay and Android AutoMotorcycle IntercomsUSB car chargersCar FM modulatorEV Car accessoriesCar StorageCar diagnostic equipmentCar Cleaning ToolsMini CompressorsParking HeatersCar fuses and holdersCar lamps
Solar panelsOFF GRID - Solar inverterSolar ControllersON GRID - Solar inverterSolar panels AccessoriesSolar panel mountingLow power controllersWind turbine
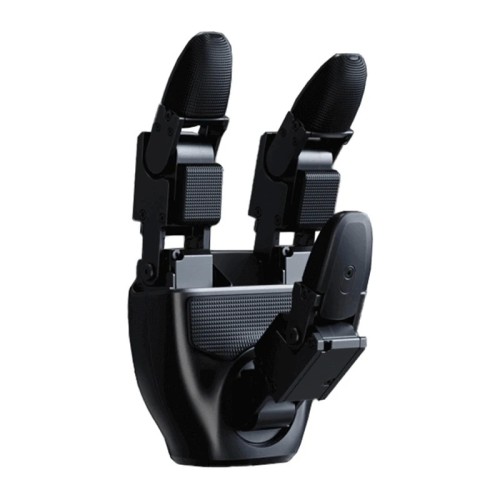
Robotic Hands UNITREE G1 Dex3-1 L+R without tactile sensors
Brand: Unitree
Product Code: DX31-214N
Availability: 4-6 business days
Planuojama gavimo data po užsakymo: 2026-10-13
Product Code: DX31-214N
Availability: 4-6 business days
Planuojama gavimo data po užsakymo: 2026-10-13
Ex Tax: 13,360.50€
UNITREE G1 Dex3-1 robotic hands (left + right) without tactile sensors
Hand Specifications
Software features
Parameters of a miniature brushless force-controlled joint
The UNITREE G1 Dex3-1 set includes a left and right three-fingered robotic hand designed to work with the UNITREE G1 humanoid robot. Each hand offers 7 degrees of freedom and utilizes 7 miniature brushless joints with force control. Hybrid force and position control allows for precise movement control, and the positioning repeatability of the fingertip is ±2 mm. Communication at a frequency of 1,000 Hz, a USB 2.0 interface, and a wide range of feedback data enable complex manipulations and precise control of the mechanism’s operation.
7 degrees of freedom for precise movementEach Dex3-1 hand has three movable fingers—the thumb has 3 degrees of freedom, the index finger has 2, and the middle finger has another 2. The range of motion of each joint allows for complex grip configurations—for the thumb, it ranges from -60° to 60°, from -35° to 60°, and from 0° to 100°, while the joints of the index and middle fingers operate within ranges of 0° to 90° and 0° to 100°, respectively. This design allows the fingers to be repositioned in multiple planes and their arrangement to be adjusted to the task at hand. The positioning repeatability of the fingertip at ±2 mm further supports tasks requiring consistent movement reproduction.
Hybrid Force Control and Advanced JointsThe UNITREE Dex3-1 utilizes hybrid force and position control, meaning control is not limited solely to setting a specific finger position. The design of each hand includes 6 miniature, directly driven brushless force-control joints and 1 joint using a geared drive. The F-1515-108 and F-1515-214 models are used, and the system allows for the control of parameters such as torque, angle, angular velocity, stiffness, and damping. For the F-1515-108, the ideal maximum torque is 0.76 Nm, while the actual torque reaches 0.49 Nm in the direction of rotation and 1.37 Nm in the opposite direction. For the F-1515-214, these values are 1.498 Nm for ideal torque and 0.86 Nm and 3.1 Nm for actual torque, respectively.
Comprehensive Operational Feedback DataThe system provides a wide range of information regarding the current state of the mechanism. Sensing data includes the joint’s mode, position, velocity, torque, and temperature, as well as voltage, current, and IMU data. The control feedback also includes the joint’s stiffness and damping coefficients. This allows for precise monitoring of the hand’s behavior during task execution and the simultaneous use of multiple parameters during motion planning and control.
1000 Hz Communication and USB 2.0The hand’s communication interface uses USB 2.0, and the communication frequency is 1000 Hz. A full data packet is 1,234 bytes on the transmit side and 1,270 bytes on the receive side. The joint control frequency is also 1,000 Hz, and High Speed Unibus is used for joint communication. These parameters provide access to a large amount of information about the hand’s status and enable frequent updates to control parameters during the execution of complex motion sequences.
Design tailored to the UNITREE G1 robotA single hand weighs 710 g, and its dimensions when extended are 175 × 88 × 77 mm. Dex3-1 can work in conjunction with the UNITREE G1 humanoid robot and enables the performance of a variety of complex manipulative tasks. The mechanism’s compact dimensions are combined with an advanced motion control system and a feedback system, providing access to a wide range of data regarding the hand’s operation.
General| Manufacturer | UNITREE |
|---|---|
| Model | DX31-214N |
| Compatibility | UNITREE G1 |
| Weight | 710 g |
|---|---|
| Dimensions | 175 × 88 × 77 mm (when extended) |
| Degrees of Freedom | Thumb ×3 Index finger ×2 Middle Finger ×2 |
| Drive Mechanism | 6 direct-drive motors 1 gear-driven motor |
| Joint Range of Motion | Thumb Joint 0: -60° to 60° Thumb joint 1: -35° to 60° Thumb joint 2: 0° to 100° Index finger joint 0: 0° to 90° Index finger joint 1: 0° to 100° Middle finger joint 0: 0° to 90° Middle finger joint 1: 0° to 100° |
| Finger tip positioning repeatability | ±2 mm |
| Operating voltage | 12–58 V |
| Quiescent current | 0.2 A at 58 V |
| Maximum current | 10 A |
| Communication interface | USB 2.0 |
| Operating temperature range | From -20°C to 60°C |
| Load conditions (palm facing down, room temperature, gripping a hard round object with a diameter of 5 cm) | Maximum weight: 500 g Maximum power: 400 W for 3 s |
| Load conditions (palm facing left, room temperature, gripping a hard round object with a diameter of 5 cm) | Maximum weight: 500 g Maximum power: 400 W for 3 s |
| Communication frequency | 1000 Hz |
|---|---|
| Number of bytes in a full data packet | Transmitter: 1234 bytes Receiver: 1270 bytes |
| Measurement feedback data | Joint mode Joint position Joint speed Joint torque Joint temperature Voltage and current IMU data |
| Control feedback data | Joint mode Joint position Joint speed Joint torque Joint stiffness coefficient Joint damping coefficient |
| Model | F-1515-108 Miniature Brushless Force-Controlled Joint F-1515-214 Miniature Brushless Force-Control Joint |
|---|---|
| Weight | 45 g |
| Dimensions | 34.8 × 23.1 × 23.3 mm |
| Gear Ratio | F-1515-108: 1:108 F-1515-214: 1:214 |
| Maximum Torque (theoretical value) | F-1515-108: 0.76 Nm F-1515-214: 1.498 Nm |
| Maximum Torque (actual value, torque in the direction of rotation) | F-1515-108: 0.49 Nm F-1515-214: 0.86 Nm |
| Maximum torque (actual value, torque opposite to the direction of rotation) | F-1515-108: 1.37 Nm F-1515-214: 3.1 Nm |
| Maximum rotational speed | F-1515-108: 23 rad/s F-1515-214: 11 rad/s |
| Maximum line current | 4.76 A |
| Control communication frequency | 1000 Hz |
| Communication method | High Speed Unibus |
| Encoder | Absolute rotor position encoder |
| Operating temperature range | From -20°C to 60°C |
| IP rating | / |
| Operating voltage | 12–24 V |
| Motor feedback | Torque Angle Angular velocity Temperature |
| Motor control commands | Torque Angle Angular velocity Stiffness Damping |
Claim orders from Stores
You can claim your purchased items within 1 - 4 work days after making an order (if product is in local warehouse).
Please wait for an email notification regarding Your order status update.
Vilnius Store address: Vytenio g. 20, LT-03229 Vilnius, Lietuva
Kaunas Store address: Pramonės pr. 4D, LT-51329, Kaunas, Lietuva
Local delivery in Lithuania
Purchased items are delivered locally through Venipak service. Depending on availability of items, orders are processed within 1-3 work days. Orders made until 1AM are shipped the same day.
Local delivery (1-4 w.d.) price for items of any size is through through courier service is 4.90€ (incl. VAT), if the amount of the shopping cart exceeds 150€ - delivery is free.
Local delivery price to Venipak parcel terminals (1-3w.d.) is 2.90€ incl. VAT, if the amount of the shopping cart exceeds 50€ - delivery is free.
Local delivery price to Omniva parcel terminals (1-3w.d.) is 3.90€ incl. VAT,if the amount of the shopping cart exceeds 70€ - delivery is free.
Payment on delivery (COD) +2.00€ (incl. VAT).
You can pay for the goods at the time of delivery to the courier in cash or by credit card. Payment to Omniva parcel terminals is only possible by bank card.
A separate delivery fee applies to oversized items, regardless of the amounts and conditions stated above.
International delivery pricing through courier service
International shipping prices depend on geographic location:
Latvia - 5.50€ (incl. VAT)
Estonia - 6.50€ (incl. VAT)
Paid orders of more than 150€ are shipped for free to Latvia and Estonia.
other countries - negiotiated individually.
International delivery pricing to Omniva/Venipak parcel terminals
Latvia - 6.00€ (incl. VAT)
Estonia - 8.50€ (incl. VAT)
Payments:
We accept payments via PayPal for orders over 20€.
